
Skills
- Python
- Path Planning (A*)
Goal
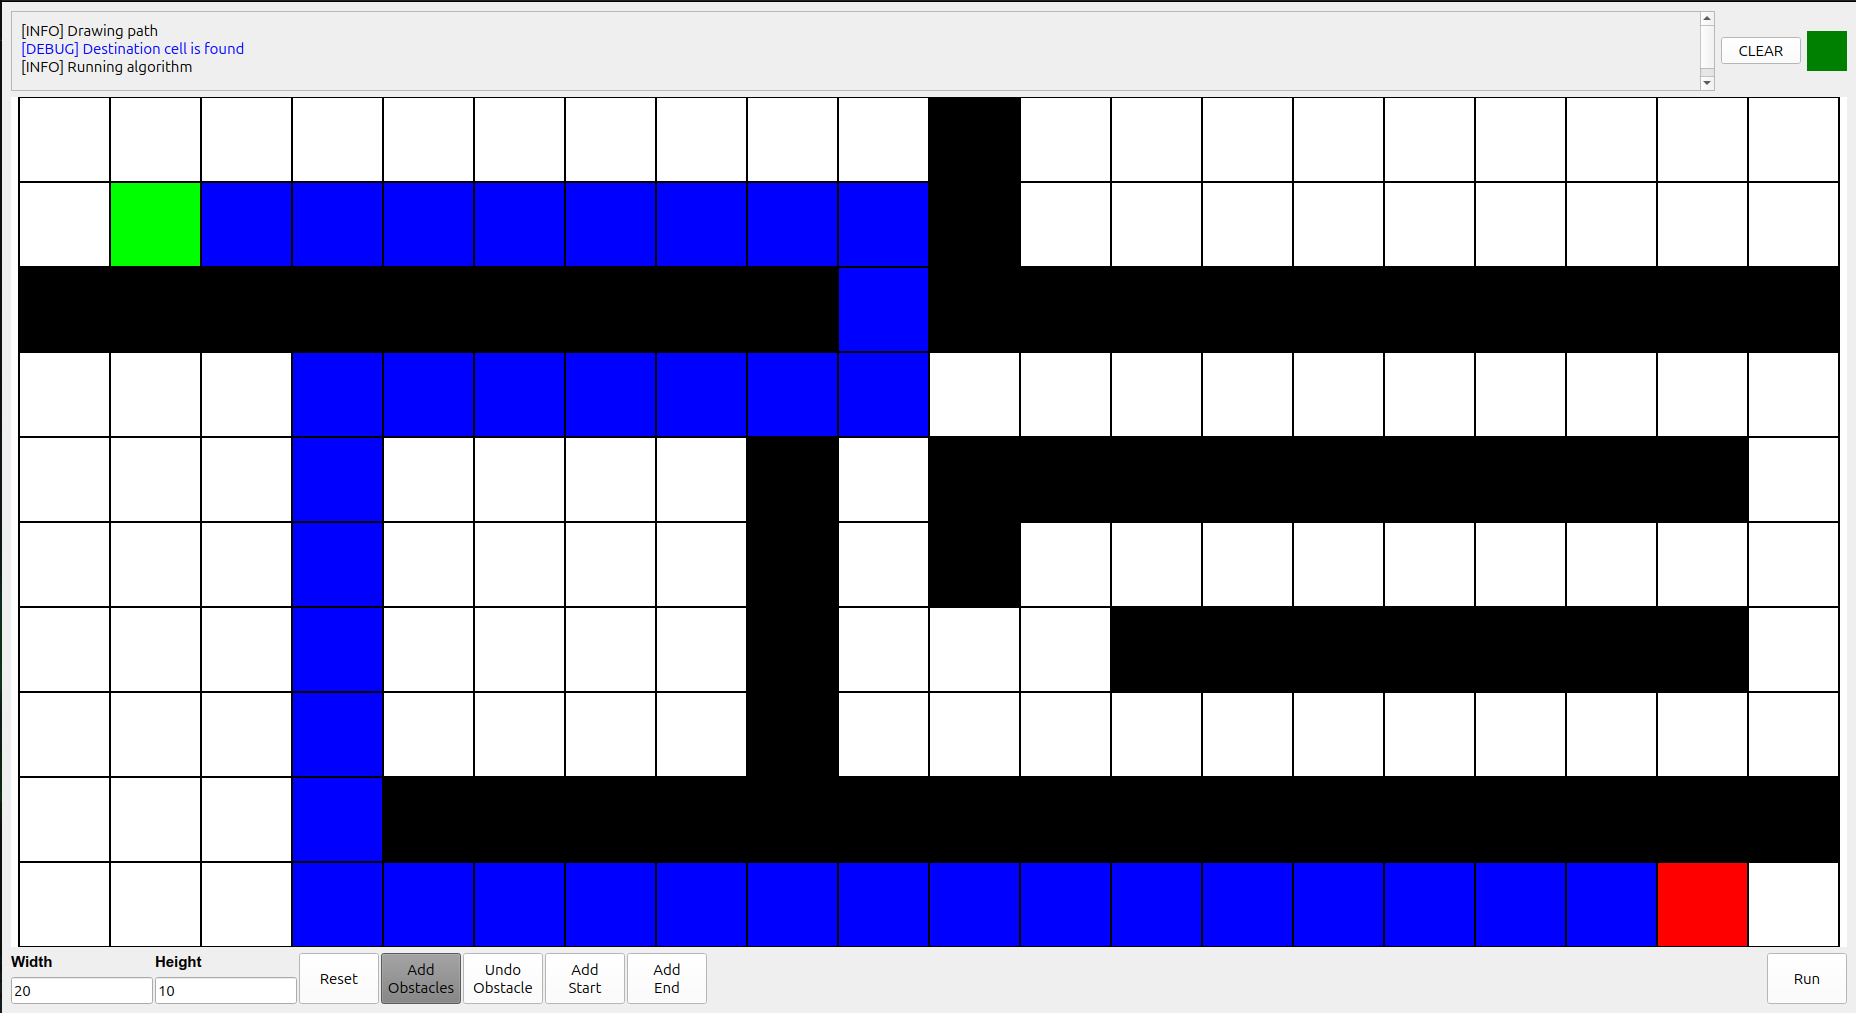
Implement the A* search algorithm in Python to plan obstacle-free routes between user-defined start and goal cells on a 2D occupancy grid, integrated with a provided GUI for visual testing
What I did
- Complete A* implementation in pure Python with no external libraries
- Four-directional motion model with uniform step cost and an admissible Euclidean-distance heuristic, guaranteeing an optimal-length path.
- O(1) closed-set membership using a Python
set, and path reconstruction via acame_frompredecessor map traced from goal back to start. - Goal test performed on node expansion rather than generation, to preserve A*’s optimality guarantee under an admissible heuristic.
- Thorough in-code documentation explaining the cost function f(n) = g(n) + h(n), the open/closed-list mechanics, and design choices made under the no-libraries constraint.
Outcome
Correct paths returned across all GUI test scenarios, with runtime well within the marking-scheme’s execution-speed threshold.